 CN
 sales@hisciences.com


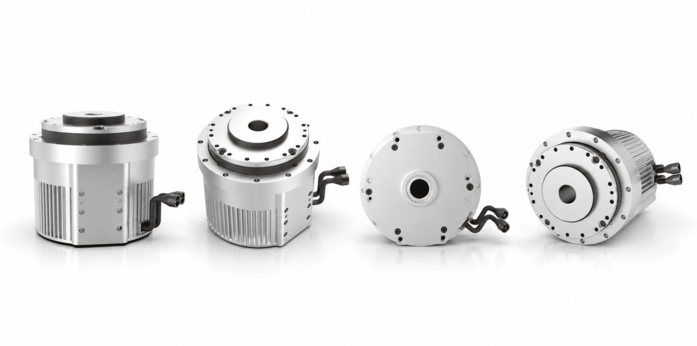
Hip and ankle joint modules have different performance requirements because they perform different functions during humanoid robot movement.
Hip joint modules support and drive leg movements, including lifting, swinging, and positioning the thigh. They generally require sufficient rated and peak torque to handle leg loads, dynamic movements, and changes in posture. Mechanical strength and output performance are also important for supporting larger movements.
Ankle joint modules help control foot orientation and positioning during standing, walking, and changes in body posture. They require precise motion control, responsive output, and suitable torque capacity to handle ground interaction and dynamic loads. Compact dimensions and low weight are also important because the ankle has limited installation space.
The final selection should be based on the robot's load conditions, motion requirements, joint structure, and available installation space.
Related Product: HISCIENCE Joint Modules
 Back to list